Seungjae (Jay) Lee
이승재
I am a Ph.D. student in the Department of Computer Science at UMD, where I am fortunate to be co-advised by Dr. Furong Huang and Dr. Jia-Bin Huang. I am also a Research Intern at NVIDIA GEAR Lab, where I have the pleasure of working with Dr. Jim Fan, Dr. Danfei Xu, and Dr. Ruijie Zheng.
Prior to joining UMD, I earned my Master's degree in the Department of Aerospace Engineering at SNU, where I was fortunate to be advised by Dr. H. Jin Kim. I also had the wonderful opportunity to work on robot learning with Dr. Lerrel Pinto of NYU.
Before that, I received Bachelor's degrees in Mechanical and Aerospace Engineering at SNU.
News
- Organizing the Scaling H2R workshop at CoRL 2026
- DynaFLIP is accepted to NeurIPS 2026
- μ0 and TAPESTRY are accepted to CoRL 2026
- Started internship at NVIDIA GEAR team
- TraceGen is accepted to CVPR 2026
- MomaGraph is accepted to ICLR 2026
Education & Experiences
Education
Ph.D. in Computer Science
University of Maryland
Advised by Professor Furong Huang and Professor Jia-Bin Huang.
Aug 2024 - Present | College Park, MD
M.S. in Aerospace Engineering
Seoul National University
Advised by Professor H. Jin Kim.
Mar 2021 - Feb 2024 | Seoul, Korea
B.S. in Mechanical & Aerospace Engineering
Seoul National University
Mar 2015 - Feb 2021 | Seoul, Korea
Experiences
NVIDIA
GEAR Team Research Intern
May 2026 - | Santa Clara, CA
Toyota Research Institute
Large Behavior Model Team Research Intern
May 2025 - Aug 2025 | Cambridge, MA
New York University
Research collaborator (Remote), advised by Professor Lerrel Pinto.
Jul 2023 - Jun 2024 | Seoul, Korea (Remote)
Samsung Electronics
Deep Learning Algorithm Team Intern
Jul 2020 - Sep 2020 | Gyunggi-do, Korea
Research
My research interest is understanding the interaction between agents and environments, and devising data-efficient decision-making (or robot learning) algorithms. Selected publications are marked with ★ below.
arXiv2026
Zhi Wang, Botao He, Kelin Yu, Seungjae Lee, Ruohan Gao, Furong Huang, Yiannis Aloimonos
Under review
project website / arXiv / github
NeurIPS2026
Jusuk Lee, Seungjae Lee, Jonghun Shin, Hoseong Jung, Sungha Kim, Daesol Cho, H. Jin Kim, Jia-Bin Huang†, Furong Huang† (†equal advising)
project website / arXiv
CoRL2026
Seungjae Lee*, Yoonkyo Jung*, Jusuk Lee, Jonghun Shin, Amir Hossein Shahidzadeh, Yao-Chih Lee, H. Jin Kim, Jia-Bin Huang†, Furong Huang† (*equal contribution, †equal advising)
project website / arXiv
IROS 2026 Workshop RoBoWoMo (🏆 Spotlight)
CoRL2026
Jeremy A. Collins, Seungjae Lee, Rachanon Wachakorn, Krishnan Srinivasan, Animesh Garg, Vitor Campagnolo Guizilini, Paarth Shah
project website
IROS2026
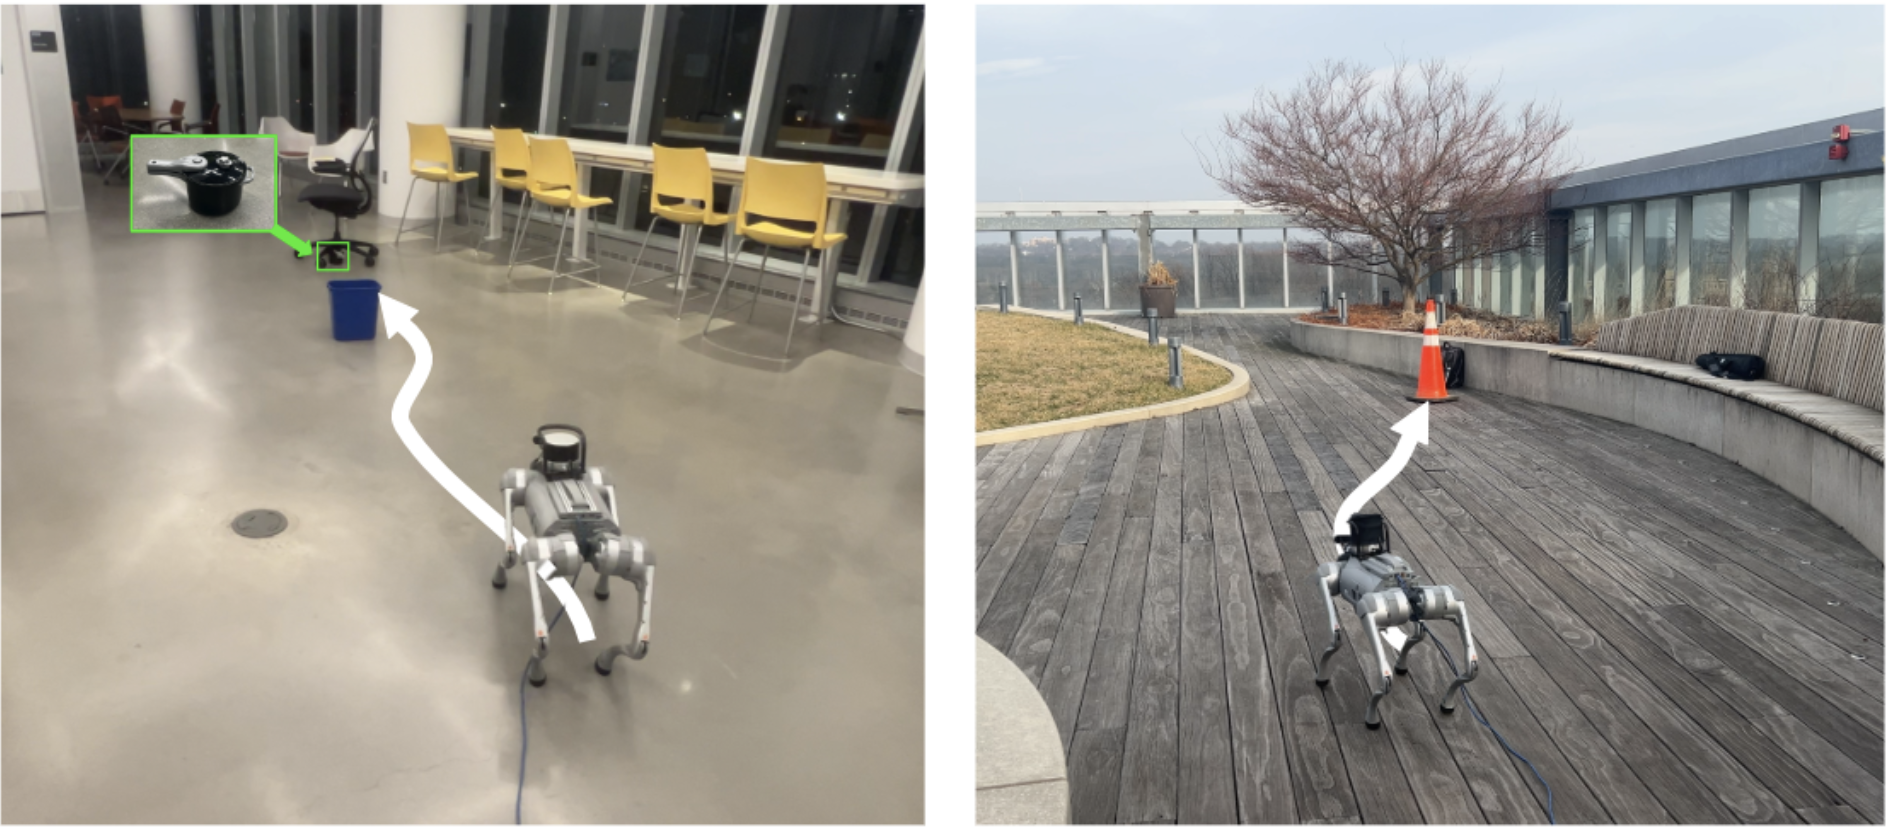
Zikui Cai*, Kaushal Janga*, Tan Dat Dao*, Seungjae Lee*, Shivin Dass, Mingyo Seo, Kaiyu Yue, Mintong Kang, Nandhu Pillai, Monte Hoover, Aadi Palnitkar, Ruchit Rawal, Ruijie Zheng, Bo Li, Yuke Zhu, Roberto Martín-Martín, Tom Goldstein, Furong Huang
arXiv
CVPR2026
Seungjae Lee*, Yoonkyo Jung*, Inkook Chun*, Yao-Chih Lee, Zikui Cai, Hongjia Huang, Aayush Talreja, Tan Dat Dao, Yongyuan Liang, Jia-Bin Huang, Furong Huang (*equal contribution)
project website / arXiv / github
ICLR2026 🏆 Oral
Yuanchen Ju, Yongyuan Liang, Yen-Jen Wang, Nandiraju Gireesh, Yuanliang Ju, Seungjae Lee, Qiao Gu, Elvis Hsieh, Furong Huang, Koushil Sreenath
project website / arXiv
NeurIPS2025
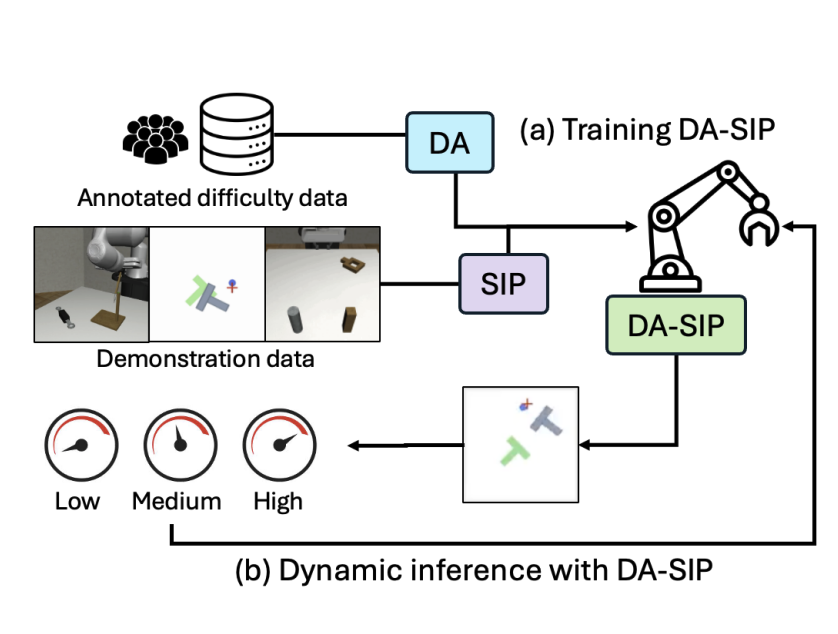
Inkook Chun, Seungjae Lee, Michael Samuel Albergo, Saining Xie, Eric Vanden-Eijnden
arXiv / github
CoRL2025
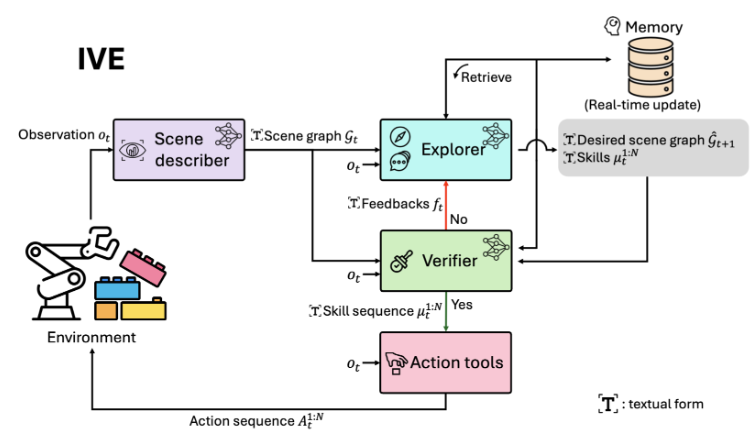
Seungjae Lee*, Daniel Ekpo*, Haowen Liu, Furong Huang†, Abhinav Shrivastava†, Jia-Bin Huang† (*equal contribution, †equal advising)
project website / arXiv
ICLRw2025
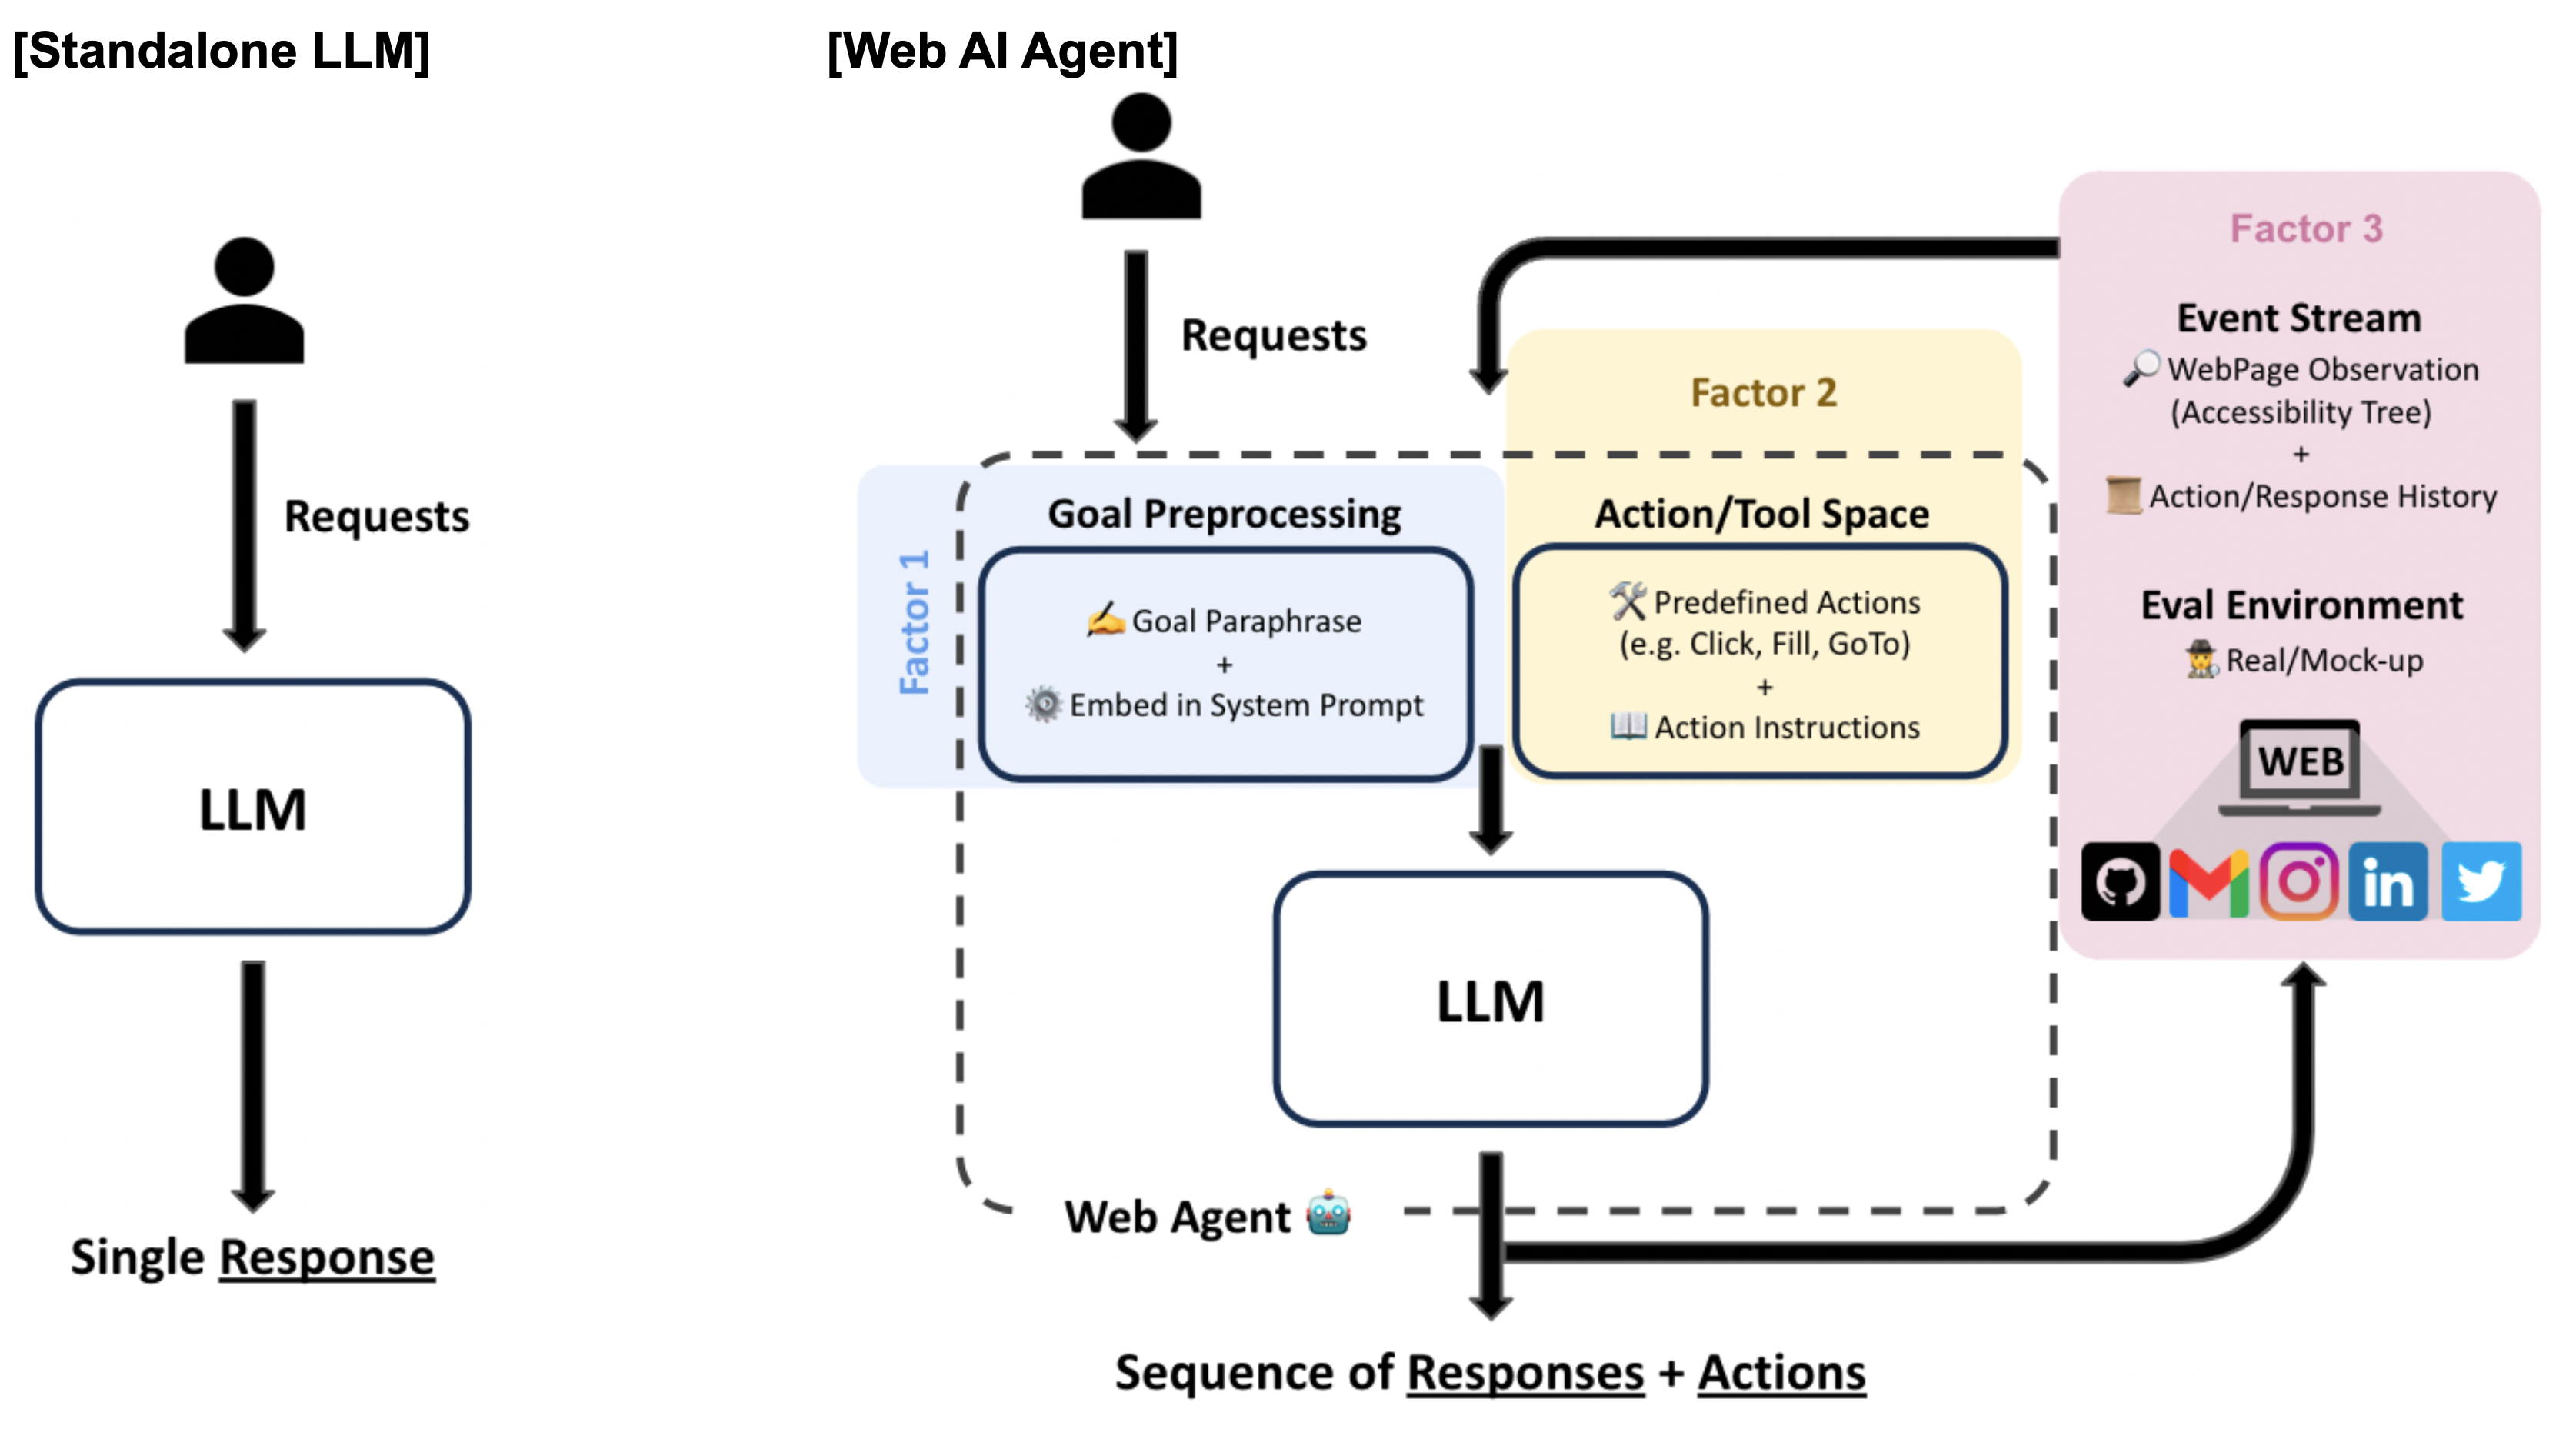
Jeffrey Yang Fan Chiang*, Seungjae Lee*, Jia-Bin Huang, Furong Huang, Yizheng Chen (*equal contribution)
project website / arXiv
ICRA2025
Haritheja Etukuru, Norihito Naka, Zijin Hu, Seungjae Lee, Julian Mehu, Aaron Edsinger, Chris Paxton, Soumith Chintala, Lerrel Pinto, Nur Muhammad Mahi Shafiullah
project website/ paper/ github
CoRL 2024 Workshop on Language and Robot Learning (🏆 Oral)
ICML2024 🏆 Spotlight, Top 3.5%
Seungjae Lee, Yibin Wang, Haritheja Etukuru, H. Jin Kim, Nur Muhammad Mahi Shafiullah, Lerrel Pinto
project website / arXiv / github / 🤗 Lerobot Library
RSS 2024 Workshop SemRob (🏆 Oral spotlights) ICML 2024 Workshop MFM-EAI (🏆️ Outstanding Paper Award - Winner)
NeurIPS2023
Seungjae Lee, Daesol Cho, Jonghae Park, H Jin Kim
arXiv
NeurIPS2023

Daesol Cho, Seungjae Lee, H Jin Kim
arXiv
ICML2023
Dongseok Shim*, Seungjae Lee*, H Jin Kim (*equal contribution)
arXiv / github
ICLR2023 🏆 Spotlight, Top 5.65%
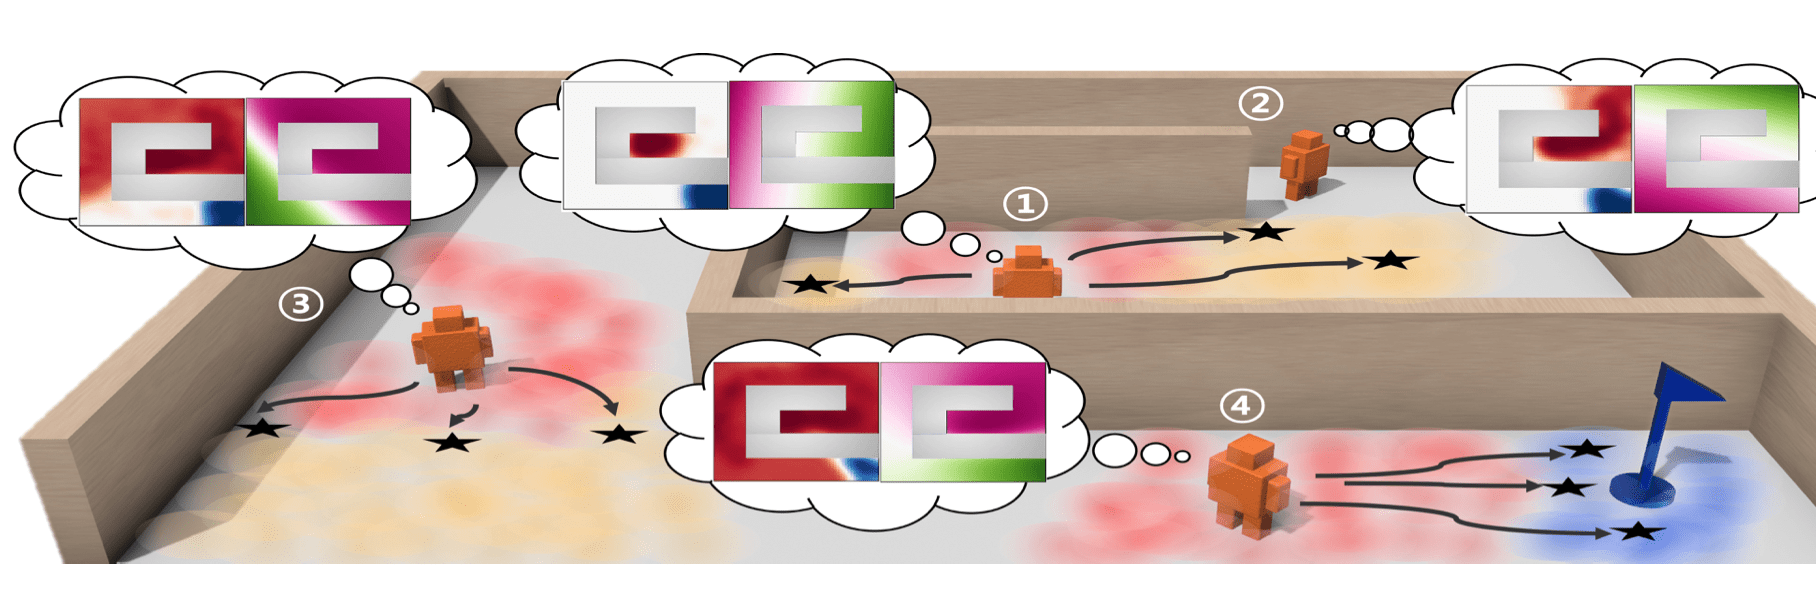
Daesol Cho*, Seungjae Lee*, H Jin Kim (*equal contribution)
arXiv / github
IJCAS2023
Seungjae Lee, Jongho Shin, Hyeong-Geun Kim, Daesol Cho, H. Jin Kim
NeurIPS2022 🏆 Oral, Top 1.76%
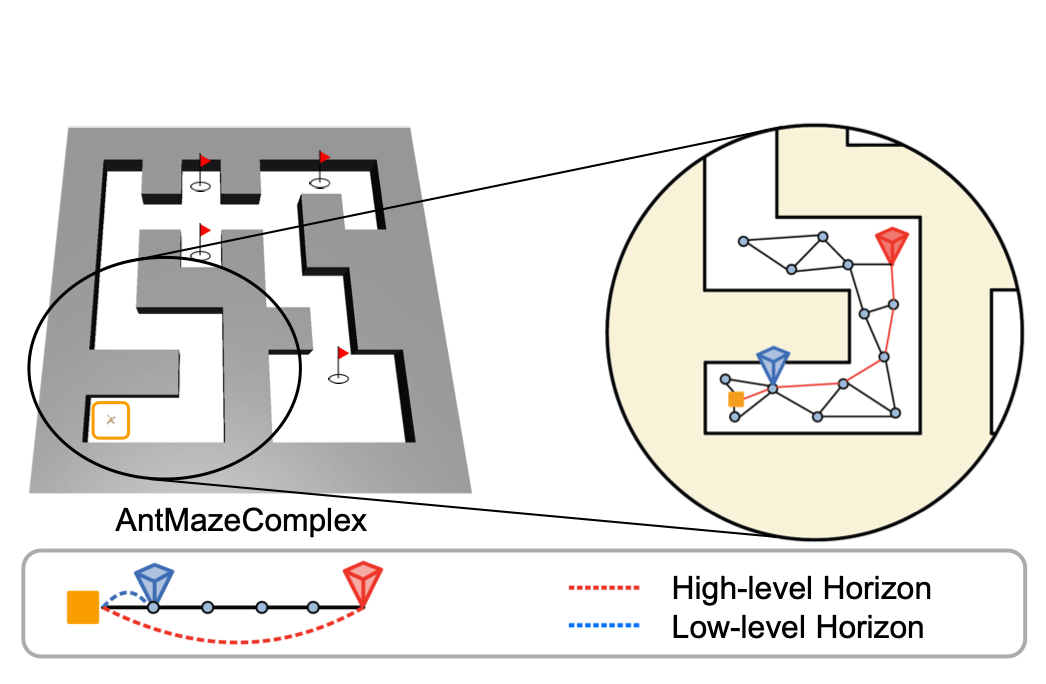
Seungjae Lee, Jigang Kim, Inkyu Jang, H. Jin Kim
arXiv / github
IROS2021
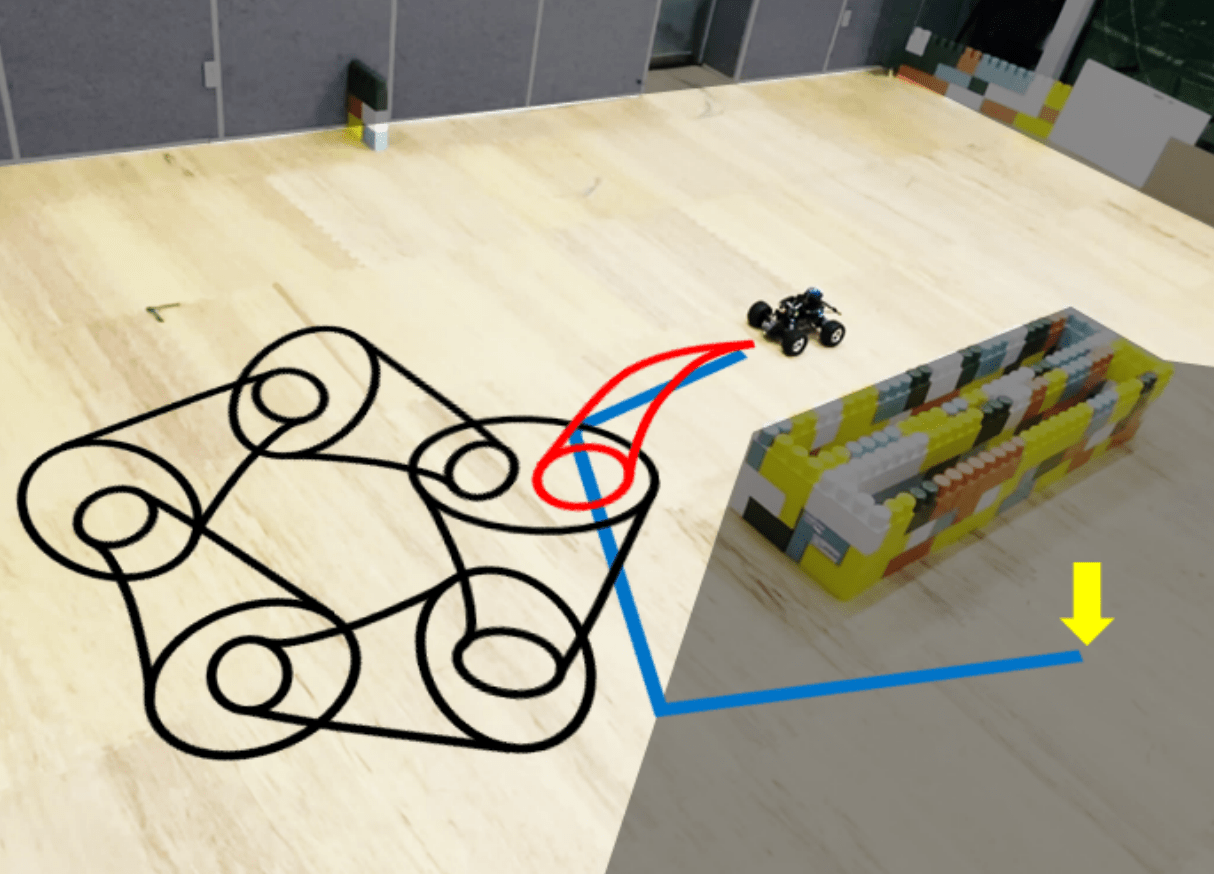
Inkyu Jang, Dongjae Lee, Seungjae Lee, H Jin Kim
arXiv
Code
Awards and Achievements
- [Awards] Graduated Summa Cum Laude, Seoul National University (1st in Department of Aerospace Engineering)
- [Scholarship] Daishin Songchon Foundation (Aug 2024 - Present)
- [Scholarship] Hyundai Motor Chung Mong-Koo Foundation (Aug 2021 - Jul2023)
- [Scholarship] OK Bae & Jung Scholarship Foundation (Mar 2020 - Dec 2020)
Academic Services
- Organizer, Scaling H2R: Scaling Laws and Diversity in Human-to-Robot, CoRL 2026
- Program Committee, RSS 2024 SemRob Workshop
- Conference reviewer for ICML'22 '24 '25
- Conference reviewer for IROS'23
- Conference reviewer for NeurIPS'23 '25 '26
- Conference reviewer for ICLR'24 '25 '26
- Conference reviewer for ICRA'24 '25
- Conference reviewer for AAAI'25
- Conference reviewer for CoRL'25 '26
- Conference reviewer for RSS'25
- Conference reviewer for CVPR'26
Teaching
- [TA] Introduction to Datascience (CMSC320), University of Maryland (2026 Spring)
- [TA] AI Planning (CMSC722), University of Maryland (2024 Fall)
- [TA] Hyundai Motor Company AI Boosting Camp, Seoul National University (2023 Summer)
- [TA] Principles of Flight Vehicle Control (M2795.002600), Seoul National University (2021 Spring)
- [TA] Basic Physics 1 (034.005), Basic Physics 2 (034.006), Seoul National University (2016 Spring, 2019 Spring, 2019 Fall)